Topics
Relations and Functions
Relations and Functions
Algebra
Inverse Trigonometric Functions
Calculus
Matrices
- Concept of Matrices
- Types of Matrices
- Equality of Matrices
- Operations on Matrices> Addition and Subtraction of Matrices
- Operations on Matrices>Scalar Multiplication
- Operations on Matrices> Matrix Multiplication
- Transpose of a Matrix
- Symmetric and Skew Symmetric Matrices
- Invertible Matrices
- Overview of Matrices
Determinants
Vectors and Three-dimensional Geometry
Continuity and Differentiability
- Continuous and Discontinuous Functions
- Algebra of Continuous Functions
- Concept of Differentiability
- Derivatives of Composite Functions
- Differentiation of Implicit Functions
- Derivative of Inverse Trigonometric Function
- Exponential and Logarithmic Functions
- Logarithmic Differentiation
- Derivatives of Functions in Parametric Forms
- Second Order Derivative
- Overview of Continuity and Differentiability
Linear Programming
Applications of Derivatives
Probability
Integrals
- Integration
- Integration as an Inverse Process of Differentiation
- Properties of Indefinite Integral
- Methods of Integration> Integration by Substitution
- Methods of Integration>Integration Using Trigonometric Identities
- Methods of Integration> Integration Using Partial Fraction
- Methods of Integration> Integration by Parts
- Integrals of Some Particular Functions
- Definite Integrals
- Fundamental Theorem of Integral Calculus
- Evaluation of Definite Integrals
- Properties of Definite Integrals
- Overview of Integrals
Sets
Applications of the Integrals
Differential Equations
- Basic Concepts of Differential Equations
- Order and Degree of a Differential Equation
- Solution of a Differential Equation
- Forms of Solving Differential Equations> Variable Separable
- Forms of Solving Differential Equations> Homogeneous Differential Equations
- Forms of Solving Differential Equations>Linear Differential Equations
- Overview of Differential Equations
Vectors
- Basic Concepts of Vector Algebra
- Direction Ratios, Direction Cosine & Direction Angles in Vector
- Types of Vectors in Algebra
- Algebra of Vectors > Addition & Subtraction of Two Vectors
- Algebra of Vectors > Scalar Multiplication
- Components of Vector in Algebra
- Vector Joining Two Points in Algebra
- Section Formula in Vector Algebra
- Product of Two Vectors > Scalar (Dot) Product
- Product of Two Vectors > Vector (Cross) Product
- Overview of Vectors
Three - Dimensional Geometry
Linear Programming
Probability
Introduction
The Multiplication Theorem of Probability is used to find the probability that two or more events occur together. It is closely connected with conditional probability, because the chance of one event may depend on whether another event has already occurred.
This theorem is especially useful in questions involving successive events, such as drawing cards, selecting balls without replacement, or performing actions step by step.
Maharashtra State Board: Class 12
Theorem: Multiplication Theorem
For two events:
-
\[P(E \cap F) = P(F) \cdot P(E | F)\],\[ P(F) \neq 0. \]
-
\[P(E \cap F) = P(E) \cdot P(F | E)\],\[ P(E) \neq 0. \]
For three events:
- \[P(E \cap F \cap G) = P(E) \cdot P(F | E) \cdot P(G | E \cap F)\], \[ P(E) \neq 0. \] and \[ P(E∩F) \neq 0. \]
When to Use This Theorem
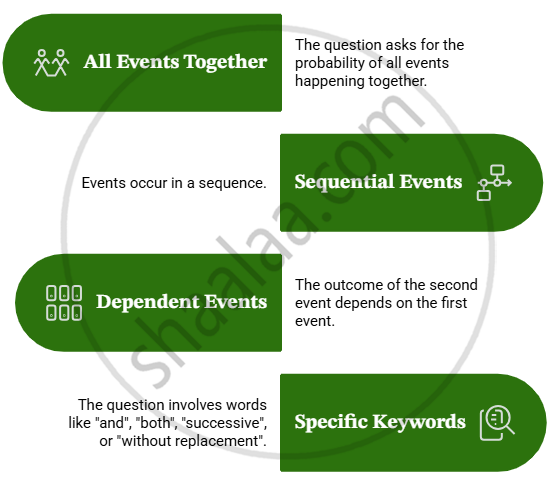
Example 1
An urn contains 10 black balls and 5 white balls. Two balls are drawn one after another without replacement. Find the probability that both balls are black.
Step 1: Define events
-
Let E = {first ball is black.}
-
Let F = {second ball is black.}
Step 2: Find probabilities
-
\[P(E) = \frac{10}{15}\]
-
After one black ball is removed, 9 black balls remain out of 14 balls. Therefore, \[P(F | E) = \frac{9}{14}\].
Step 3: Apply multiplication theorem
Answer: Probability that both balls are black = \[\frac{3}{7}\].
Key Points: Multiplication Theorem on Probability
-
Multiplication theorem is used to find the probability of simultaneous occurrence of events.
-
For two events: \[P(E \cap F) = P(E) \cdot P(F | E)\]
-
Another equivalent form is \[P(E \cap F) = P(F) \cdot P(E | F)\].
-
For three events: \[P(E \cap F \cap G) = P(E) \cdot P(F | E) \cdot P(G | E \cap F)\].
-
Most “without replacement” questions are solved using this theorem.
-
Always define events before solving a probability problem.
Test Yourself
Shaalaa.com | Probability part 12 (Multiplication theorem on Probability)
Related QuestionsVIEW ALL [28]
Read the following passage and answer the questions given below:
In an Office three employees Jayant, Sonia and Oliver process incoming copies of a certain form. Jayant processes 50% of the forms, Sonia processes 20% and Oliver the remaining 30% of the forms. Jayant has an error rate of 0.06, Sonia has an error rate of 0.04 and Oliver has an error rate of 0.03. |
Based on the above information, answer the following questions.
- Find the probability that Sonia processed the form and committed an error.
- Find the total probability of committing an error in processing the form.
- The manager of the Company wants to do a quality check. During inspection, he selects a form at random from the days output of processed form. If the form selected at random has an error, find the probability that the form is not processed by Jayant.
OR
Let E be the event of committing an error in processing the form and let E1, E2 and E3 be the events that Jayant, Sonia and Oliver processed the form. Find the value of `sum_(i = 1)^3P(E_i|E)`.
