Definitions [5]
The two mutually perpendicular number lines intersecting each other at their zeroes are called rectangular axes or coordinate axes, or axes of reference.
The position of a point in a plane is expressed by a pair of numbers, one concerning the x-axis and the other concerning the y-axis. called co-ordinates.
-
x → distance from y-axis (abscissa)
-
y → distance from x-axis (ordinate)
If a directed line makes angles \[\alpha\], \[\beta\], and \[\gamma\] with the positive x-, y-, and z-axes respectively, then these are called the direction angles of the line.
The cosines of these angles are called the direction cosines of the line.
So, the direction cosines are written as (l, m, n).
\[ \boxed{\,l^{2} + m^{2} + n^{2} = 1\,} \]
Any three numbers proportional to the direction cosines of a line are called the direction ratios of the line.
If (a, b, c) are direction ratios, then:
Formulae [9]
| Sr. No. | Name | Condition | Formula |
|---|---|---|---|
| i. | Distance Formula | Two points P(x₁, y₁), Q(x₂, y₂) | \[\mathrm{d(PQ)}=\sqrt{\left(x_{2}-x_{1}\right)^{2}+\left(y_{2}-y_{1}\right)^{2}}\] |
| a. | Internal Division | P divides AB in the ratio m: n | \[\mathrm{P\equiv\left(\frac{mx_{2}+nx_{1}}{m+n},\frac{my_{2}+ny_{1}}{m+n}\right)}\] |
| b. | Midpoint Formula | P is the midpoint of AB | \[\mathrm{P}\equiv\left(\frac{x_{1}+x_{2}}{2},\frac{y_{1}+y_{2}}{2}\right)\] |
| c. | External Division | P divides AB externally in m: n | \[\mathrm{P\equiv\left(\frac{mx_{2}-nx_{1}}{m-n},\frac{my_{2}-ny_{1}}{m-n}\right)}\] |
| iii. | Centroid Formula | Triangle with vertices A, B, C | \[\left(\frac{x_1+x_2+x_3}{3},\frac{y_1+y_2+y_3}{3}\right)\] |
If the direction ratios of two lines are:
First line: \[(a_1, b_1, c_1)\]
Second line: \[(a_2, b_2, c_2)\]
then the cosine of the angle \[\theta\] between them is:
If the direction cosines of the two lines are
\[(l_1, m_1, n_1)\] and \[(l_2, m_2, n_2)\], then:
If the direction ratios are \[(a_1, b_1, c_1)\] and \[(a_2, b_2, c_2)\], then:
\[SD=\left|\frac{\left(a_{2}-a_{1}\right)\times b}{\left|b\right|}\right|\]
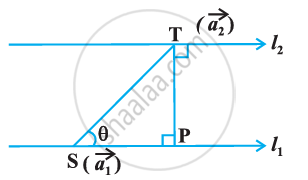
If the lines are \[ \vec{r} = \vec{a}_{1} + \lambda\vec{b}_{1} \] and \[ \vec{r} = \vec{a}_{2} + \mu\vec{b}_{2}, \]
then \[ \vec{a}_{1}, \vec{a}_{2} \] are position vectors of points on the lines and \[ \vec{b}_{1}, \vec{b}_{2} \] are their direction vectors.
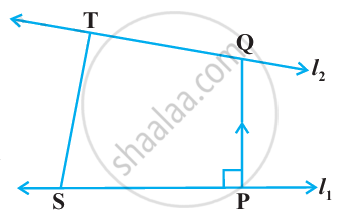
Vector Form:
\[\mathbf{d}=\left|\frac{(\overline{\mathbf{b}}_{1}\times\overline{\mathbf{b}}_{2}).(\overline{\mathbf{a}}_{2}-\overline{\mathbf{a}}_{1})}{\left|\overline{\mathbf{b}}_{1}\times\overline{\mathbf{b}}_{2}\right|}\right|\]
Cartesian Form:
\[\mathbf{d}=\left|\frac{ \begin{vmatrix} x_2-x_1 & y_2-y_1 & z_2-z_1 \\ \mathbf{a}_1 & \mathbf{b}_1 & \mathbf{c}_1 \\ \mathbf{a}_2 & \mathbf{b}_2 & \mathbf{c}_2 \end{vmatrix}}{\sqrt{\left(\mathbf{a}_1\mathbf{b}_2-\mathbf{a}_2\mathbf{b}_1\right)^2+\left(\mathbf{a}_1\mathbf{c}_2-\mathbf{a}_2\mathbf{c}_1\right)^2+\left(\mathbf{b}_1\mathbf{c}_2-\mathbf{b}_2\mathbf{c}_1\right)^2}}\right|\]
Vector Form:
\[\cos\theta=\left|\frac{\overline{\mathbf{n₁}}.\overline{\mathbf{n₂}}}{\left|\overline{\mathbf{n₁}}\right|.\left|\overline{\mathbf{n₂}}\right|}\right|\]
Cartesian Form:
\[\cos\theta=\left|\frac{\mathrm{a}_{1}\mathrm{a}_{2}+\mathrm{b}_{1}\mathrm{b}_{2}+\mathrm{c}_{1}\mathrm{c}_{2}}{\sqrt{\mathrm{a}_{1}^{2}+\mathrm{b}_{1}^{2}+\mathrm{c}_{1}^{2}}\sqrt{\mathrm{a}_{2}^{2}+\mathrm{b}_{2}^{2}+\mathrm{c}_{2}^{2}}}\right|\]
Vector Form:
\[\sin\theta=\left|\frac{\overline{\mathbf{b}}.\overline{\mathbf{n}}}{\left|\overline{\mathbf{b}}\right|.\left|\overline{\mathbf{n}}\right|}\right|\]
Cartesian Form:
\[\mathrm{sin}\theta=\frac{\mathrm{aa}_{1}+\mathrm{bb}_{1}+\mathrm{cc}_{1}}{\sqrt{\mathrm{a}^{2}+\mathrm{b}^{2}+\mathrm{c}^{2}}\sqrt{\mathrm{a}_{1}^{2}+\mathrm{b}_{1}^{2}+\mathrm{c}_{1}^{2}}}\]
Vector Form:
\[\mathbf{d}=\frac{\left|\left(\overline{\mathbf{a}}.\overline{\mathbf{n}}\right)-\mathbf{p}\right|}{\left|\overline{\mathbf{n}}\right|}\]
Cartesian Form:
\[\mathbf{d}=\left|\frac{\mathbf{a}x_{1}+\mathbf{b}y_{1}+\mathbf{c}z_{1}+\mathbf{d}}{\sqrt{\mathbf{a}^{2}+\mathbf{b}^{2}+\mathbf{c}^{2}}}\right|\]
Key Points
Sign Convention
-
Right of y-axis → +x
-
Left of y-axis → −x
-
Above x-axis → +y
-
Below x-axis → −y
Standard Line Results
-
x = 0 → y-axis
-
y = 0 → x-axis
-
x = a → line parallel to the y-axis
-
y = b → line parallel to the x-axis
Quadrant Reminder
| Quadrant | Sign of (x, y) |
|---|---|
| I | (+, +) |
| II | (−, +) |
| III | (−, −) |
| IV | (+, −) |
-
Direction Cosines (DCs) of a line: \[(l, m, n) = (\cos \alpha, \cos \beta, \cos \gamma)\].
-
Main identity: \[l^2 + m^2 + n^2 = 1\].
-
Direction Ratios (DRs): Are proportional to DCs.
-
Relation between DRs and DCs: If DRs are (a, b, c), then DCs are proportional to (a, b, c) divided by \[\sqrt{a^2 + b^2 + c^2}\].
-
DRs for two points: For points \[P(x_1, y_1, z_1)\] and \[Q(x_2, y_2, z_2)\], DRs are \[(x_2 - x_1, y_2 - y_1, z_2 - z_1)\].
-
The angle between two lines depends only on their directions.
-
If lines do not pass through the origin, imagine parallel lines through the origin.
-
The dot-product formula is the main method for solving these questions.
-
In symmetric form, denominators give direction ratios.
-
Zero dot product means perpendicular lines.
-
Proportional direction ratios mean parallel lines.
-
The required angle is generally the acute angle.
-
Intersecting lines: SD = 0
-
Parallel lines: \[SD = \frac{|(\vec{a}_2 - \vec{a}_1) \times \vec{b}|}{|\vec{b}|}\]
-
Skew lines: \[SD = \frac{|(\vec{a}_2 - \vec{a}_1) \cdot (\vec{b}_1 \times \vec{b}_2)|}{|\vec{b}_1 \times \vec{b}_2|}\]
| Case | Vector Form | Cartesian Form |
|---|---|---|
| 1. Normal form (given normal vector) | \[\overline{\mathbf{r}}.\hat{\mathbf{n}}=\mathbf{p}\] | ax + by + cz + d = 0 |
| 2. Through a point (x₁, y₁, z₁) | \[\begin{bmatrix} \mathbf{\overline{r}}-\mathbf{\overline{a}} \end{bmatrix}.\mathbf{\overline{n}}=\mathbf{0}\] | a(x−x₁) + b(y−y₁) + c(z−z₁) = 0 |
| 3. Through point + parallel to two vectors | \[\begin{bmatrix} \overline{\mathbf{r}}\overline{\mathbf{b}}\overline{\mathbf{c}} \end{bmatrix}= \begin{bmatrix} \overline{\mathbf{a}}\overline{\mathbf{b}}\overline{\mathbf{c}} \end{bmatrix}\] | \[\begin{vmatrix} x-x_1 & y-y_1 & z-z_1 \\ \mathbf{b}_1 & \mathbf{b}_2 & \mathbf{b}_3 \\ \mathbf{c}_1 & \mathbf{c}_2 & \mathbf{c}_3 \end{vmatrix}=0\] |
| 4. Through three non-collinear points | \[(\mathbf{r-a})\cdot[(\mathbf{b-a})\times(\mathbf{c-a})]=0\] | \[\begin{vmatrix} x-x_1 & y-y_1 & z-z_1 \\ x_2-x_1 & y_2-y_1 & z_2-z_1 \\ x_3-x_1 & y_3-y_1 & z_3-z_1 \end{vmatrix}=0\] |
| 5. Through the intersection of two planes | \[\left(\overline{\mathbf{r}}.\overline{\mathbf{n}}_1-\mathbf{d}_1\right)+\lambda\left(\overline{\mathbf{r}}.\overline{\mathbf{n}}_2-\mathbf{d}_2\right)=0\] | (a₁x + b₁y + c₁z + d₁) + λ(a₂x + b₂y + c₂z + d₂) = 0 |
Equation of a Plane in Intercept form:
\[\frac{x}{a}+\frac{y}{b}+\frac{z}{c}=1\]
Distance of the Plane from Origin is
\[d=\frac{1}{\sqrt{\frac{1}{a^{2}}+\frac{1}{b^{2}}+\frac{1}{c^{2}}}}\]
Condition for Perpendicularity:
\[\overline{\mathbf{b}}=\lambda\overline{\mathbf{n}}\], λ is a parameter
\[\frac{\mathbf{a}_{1}}{\mathbf{a}}=\frac{\mathbf{b}_{1}}{\mathbf{b}}=\frac{\mathbf{c}_{1}}{\mathbf{c}}\]
Condition for Parallelism:
The line is parallel to the plane, if
\[\overline{\mathbf{b}}.\overline{\mathbf{n}}=0\]
aa₁ + bb₁ + cc₁ = 0
Concepts [10]
- Foundation of Coordinate Geometry
- Direction Cosines and Direction Ratios of a Line
- Straight Line In Space
- Angle Between Two Lines
- Coplanar and Intersection of Two Lines
- Shortest Distance Between Two Lines
- Plane with Normal Form
- Different Forms of Equation of a Plane
- Angle Between Two Planes
- Distance of a Point from a Plane
