Definitions [16]
A scalar quantity is a physical quantity that has magnitude only.
A vector quantity is a physical quantity that has magnitude as well as direction.
A vector is a quantity that has magnitude as well as direction. Geometrically, a vector is represented by a directed line segment such as \[\vec{AB}\], where A is the initial point and B is the terminal point.
The magnitude of vector \[\vec{AB}\] is the length of the directed line segment AB. It is written as \[|\vec{AB}|\], \[|\vec{a}|\], or simply a. The magnitude of a vector is never negative because it represents length.
In three-dimensional geometry, the vector drawn from the origin O(0, 0, 0) to a point P(x, y, z) is called the position vector of the point P. It is written as \[\vec{OP}\]. If point P(x, y, z) is given, then the magnitude of its position vector is:
If l, m, n are direction cosines of a line and if a, b, c are real numbers such that \[\frac{\mathrm{a}}{l}=\frac{\mathrm{b}}{\mathrm{m}}=\frac{\mathrm{c}}{\mathrm{n}}=\lambda,\] then a, b, c are called direction ratios of that line.
\[ \boxed{\,\frac{a}{\sqrt{a^{2} + b^{2} + c^{2}}}, \qquad \frac{b}{\sqrt{a^{2} + b^{2} + c^{2}}}, \qquad \frac{c}{\sqrt{a^{2} + b^{2} + c^{2}}}\,} \]
The angles made by a vector with the positive directions of the X-axis, Y-axis and Z-axis are called direction angles of the vector, denoted by α, β, and γ.
\[ l = \cos\alpha, \quad m = \cos\beta, \quad n = \cos\gamma, \]
\[ \boxed{\,\cos^{2}\alpha + \cos^{2}\beta + \cos^{2}\gamma = 1\,} \]
If α, β and γ are the direction angles of a vector, then the cosines of these angles, i.e.
l = cosα, m = cosβ, n = cosγ
are called the direction cosines of the vector.
If \[ P(x,y,z) \] is a point and \[ \vec{OP} \] is its position vector, then
\[ r = |\vec{OP}| = \sqrt{x^{2} + y^{2} + z^{2}} \]
and
\[ \boxed{\,\cos\alpha = \frac{x}{r}, \qquad \cos\beta = \frac{y}{r}, \qquad \cos\gamma = \frac{z}{r}\,} \]
If \[\vec{a}\] is a vector and \[\lambda\] is a scalar, then \[\lambda\vec{a}\] is called the multiplication of the vector \[\vec{a}\] by the scalar \[\lambda\]. The resulting quantity is also a vector, and it is collinear with \[\vec{a}\].
If P(x, y, z) is a point, then its position vector is
This is called the component form of a vector.
General Component Form:
If \[ \vec{a} = a_{1}\hat{i} + a_{2}\hat{j} + a_{3}\hat{k}, \]
then \[ a_{1}, a_{2}, a_{3} \] are called the components of \[ \vec{a}. \]
a and b are two non-collinear vectors. A vector r is coplanar with a and b if and only if there exists a unique scalar λ₁ and λ₂ such that r = λ₁a + λ₂b
Three vectors a₁i + a₂j + a₃k, b₁i + b₂j + b₃k and c₁i + c₂j + c₃k are coplanar, if \[\begin{vmatrix} a_{1} & a_{2} & a_{3} \\ b_{1} & b_{2} & b_{3} \\ c_{1} & c_{2} & c_{3} \end{vmatrix}=0.\]
Four points with position vectors a = a₁i + a₂j + a₃k, b = b₁i + b₂j + b₃k, c = c₁i + c₂j + c₃k and d = d₁i + d₂j + d₃k will be coplanar iff
\[\begin{vmatrix} a_1 & a_2 & a_3 & 1 \\ b_1 & b_2 & b_3 & 1 \\ c_1 & c_2 & c_3 & 1 \\ d_1 & d_2 & d_3 & 1 \end{vmatrix}=0.\]
In general, if a₁, a₂, …, aₙ are n vectors and t₁, t₂, …, tₙ are n scalars, then linear combination of vectors a₁, a₂, …, aₙ is t₁a₁ + t₂a₂ + … + tₙaₙ.
-
For 2 vectors:
\[\overline{\mathbf{r}}=x\overline{\mathbf{a}}+y\overline{\mathbf{b}}\] -
For 3 vectors:
\[\mathbf{\overline{r}}=x\mathbf{\overline{a}}+y\mathbf{\overline{b}}+\mathbf{z}\mathbf{\overline{c}}\]
Two vectors a and b are collinear if there exists a scalar λ such that a = λb.
Three points A(a), B(b) and C(c) are collinear iff ∃ non-zero scalars x, y, z such that xa + yb + zc = 0, where x + y + z = 0.
Three points A(a), B(b) and C(c) are collinear if AB × BC = 0 i.e. a × b + b × c + c × a = 0.
If \[\vec{a}\] and \[\vec{b}\] are two vectors and \[\theta\] is the angle between them, then their scalar product is given by:
Projection is the part of one vector in the direction of another vector.
Scalar projection of \[\vec{a}\] on \[\vec{b}\]
Vector projection of \[\vec{a}\] on \[\vec{b}\]
If \[\vec{a}\] and \[\vec{b}\] are two non-zero vectors vectors with angle \[\theta\] between them, then their vector product is: \[\vec{a} \times \vec{b} = |\vec{a}| |\vec{b}| \sin \theta \hat{n}\]
where \[\hat{n}\] is a unit vector perpendicular to both \[\vec{a}\] and \[\vec{b}\], in the direction given by the right-hand rule.
Cross Product Angle: \[\sin \theta = \frac{|\vec{a} \times \vec{b}|}{|\vec{a}| |\vec{b}|}\]
Formulae [5]
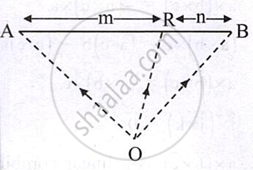
If R (r̄) is the mid-point of the line segment joining the points A (ā) and B (b̄), then
\[\overline{\mathbf{r}}=\frac{\overline{\mathbf{a}}+\overline{\mathbf{b}}}{2}\]
\[\mathbf{\overline{r}}=\mathbf{\frac{m\overline{b}+n\overline{a}}{m+n}}\]
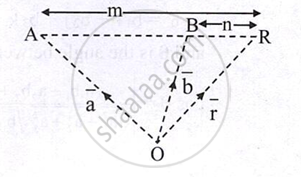
\[\overline{\mathrm{r}}=\frac{\mathrm{m\overline{b}-n\overline{a}}}{\mathrm{m-n}}\]
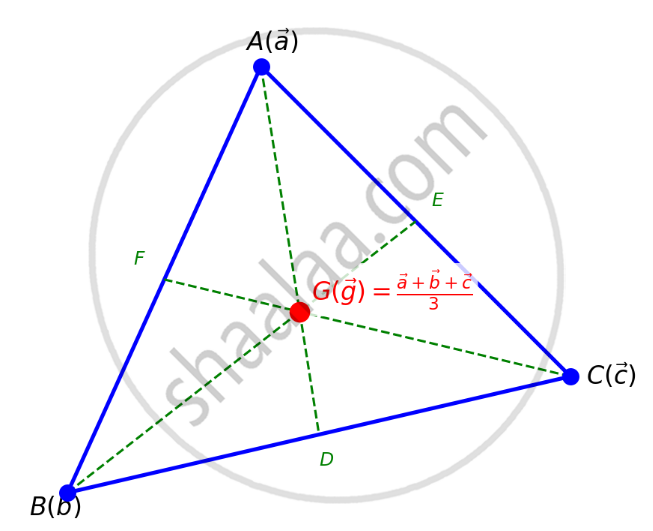
Centroid of Triangle:
\[\mathbf{\overline{g}}=\frac{\mathbf{\overline{a}}+\mathbf{\overline{b}}+\mathbf{\overline{c}}}{3}\]
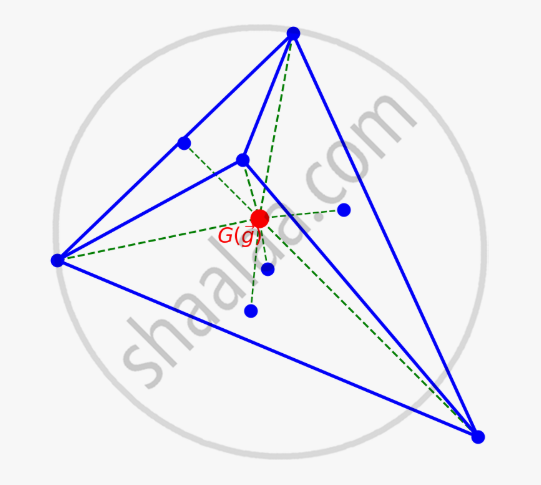
Centroid of Tetrahedron:
\[\overline{\mathbf{g}}=\frac{\overline{\mathbf{a}}+\overline{\mathbf{b}}+\overline{\mathbf{c}}+\overline{\mathbf{d}}}{4}\]
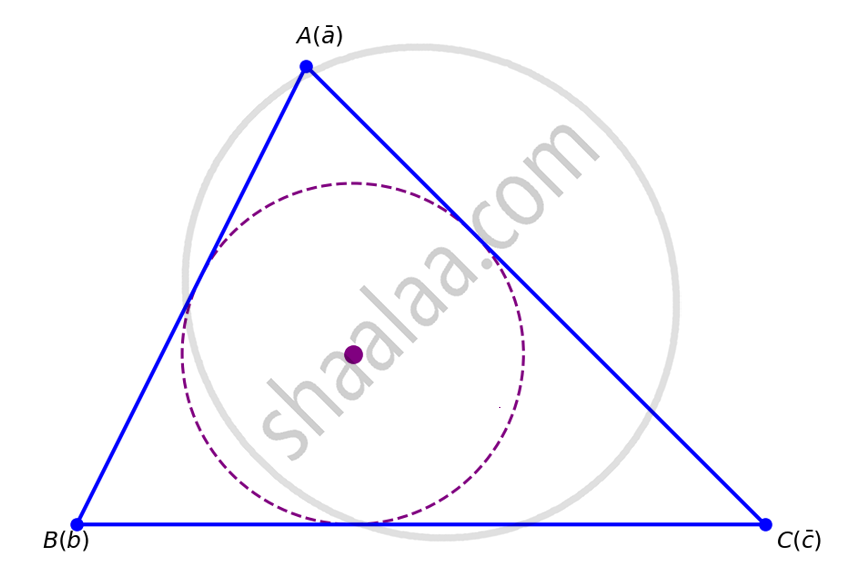
Incentre of Triangle:
\[\overline{\mathrm{h}}=\frac{\left|\overline{\mathrm{AB}}\right|\overline{\mathrm{c}}+\left|\overline{\mathrm{BC}}\right|\overline{\mathrm{a}}+\left|\overline{\mathrm{AC}}\right|\overline{\mathrm{b}}}{\left|\overline{\mathrm{AB}}\right|+\left|\overline{\mathrm{BC}}\right|+\left|\overline{\mathrm{AC}}\right|}\]
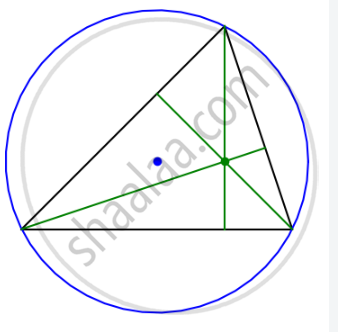
Orthocentre of Triangle:
\[\overline{\mathrm{p}}=\frac{\tan A\left(\overline{\mathrm{a}}\right)+\tan B\left(\overline{\mathrm{b}}\right)+\tan C\left(\overline{\mathrm{c}}\right)}{\tan A+\tan B+\tan C}\]
Magnitude of Vector: \[\mid r\mid=\sqrt{x^{2}+y^{2}}\]
\[\theta=\tan^{-1}\left(\frac{y}{x}\right)\]
Theorems and Laws [3]
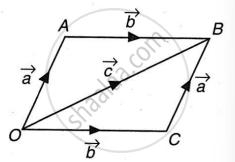
If two vectors are represented by two adjacent sides of a parallelogram, then their resultant is represented by the diagonal passing through their common initial point.
The difference of two vectors is obtained by adding the negative of one vector.
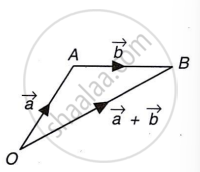
If two vectors are represented by two sides of a triangle taken in order, then their sum is represented by the third side of the triangle taken in the opposite order.
Key Points
-
Scalars have only magnitude.
-
Vectors have magnitude and direction.
-
Vectors are represented by directed line segments.
-
\[\vec{AB}\] represents a vector from A to B.
-
Magnitude of a vector is its length and is always non-negative.
-
\[\vec{OP}\] is the position vector of point \[P(x, y, z)\].
-
\[|\vec{OP}| = \sqrt{x^2 + y^2 + z^2}\].
-
Direction angles are the angles a line makes with the positive coordinate axes.
-
Direction cosines are \[\cos \alpha\], \[\cos \beta\], and \[\cos \gamma\].
-
If direction cosines are (l, m, n), then \[l^2 + m^2 + n^2 = 1\].
-
Direction ratios are any numbers proportional to direction cosines.
-
If direction ratios are (a, b, c), then corresponding direction cosines are:
-
For points \[A(x_1, y_1, z_1)\], \[B(x_2, y_2, z_2)\], direction ratios of AB are \[(x_2 - x_1, y_2 - y_1, z_2 - z_1)\].
-
Angle between two lines can be found using either direction cosines or direction ratios.
| Type of Vector | Definition | Main Property | Simple Recall Cue |
|---|---|---|---|
| Zero vector | Initial and terminal points are same | Magnitude = 0 | No displacement |
| Unit vector | Magnitude is 1 | Gives direction conveniently | Length 1 |
| Coinitial vectors | Same starting point | Start together | Common origin |
| Collinear vectors | Parallel to same line | Lie along one line | Same line |
| Equal vectors | Same magnitude and direction | Position may differ | Same length + same direction |
| Negative vectors | Same magnitude, opposite direction | Sign changes direction | Reverse arrow |
| Free vectors | Can shift parallelly without change | Independent of position | Slide without changing |
-
A vector has both magnitude and direction.
-
Resultant means the combined effect of two or more vectors.
-
Triangle law uses head-to-tail arrangement.
-
Parallelogram law uses adjacent sides from the same initial point.
-
Vector addition is commutative and associative.
-
Zero vector is the identity element for vector addition.
-
Difference of vectors is obtained by adding the negative of a vector.
-
Multiplication of a vector by a scalar gives a new vector collinear with the original.
-
Magnitude scales by \[|\lambda|\]; direction depends on the sign of \[\lambda\].
-
\[\lambda > 0\]: Same direction; \[\lambda < 0\]: Opposite direction.
-
\[\lambda = 0\]: Result is the null vector.
-
Used extensively in components form: multiply each component by the scalar.
- Section formula gives the position vector of a point dividing a line segment in a given ratio.
-
For internal division, use \(\dfrac{m\vec{b}+n\vec{a}}{m+n}\).
-
For external division, use \(\dfrac{m\vec{b}-n\vec{a}}{m-n}\).
-
Midpoint is the special case when the ratio is \(1:1\).
-
Centroid formulas are natural extensions of the same averaging idea.
- The dot product of two vectors is a scalar quantity.
- The dot product uses the cosine of the angle between the vectors.
\[ \vec{a} \cdot \vec{b} = |\vec{a}||\vec{b}| \cos\theta \] - The dot product is useful in finding the angle between two vectors and projection.
- For two non-zero vectors, \[ \vec{a} \cdot \vec{b} = 0 \] indicates that the vectors are perpendicular.
- The cross product of two vectors is a vector quantity.
- The cross product uses the sine of the angle between the vectors.
\[ \vec{a} \times \vec{b} = |\vec{a}||\vec{b}| \sin\theta\,\hat{n} \] - The resulting vector is perpendicular to both vectors.
- The cross product is useful in area and direction problems.
- For two non-zero vectors, \[ \vec{a} \times \vec{b} = \vec{0} \] indicates that the vectors are parallel or collinear.
- Area of Triangle: \[ \frac{1}{2}|\vec{a} \times \vec{b}| \]
- Area of Parallelogram: \[ |\vec{a} \times \vec{b}| \]
Concepts [12]
- Basic Concepts of Vector Algebra
- Direction Ratios, Direction Cosine & Direction Angles in Vector
- Types of Vectors in Algebra
- Algebra of Vectors > Addition & Subtraction of Two Vectors
- Algebra of Vectors > Scalar Multiplication
- Components of Vector in Algebra
- Section Formula in Vector Algebra
- Vectors in Coordinate Geometry
- Parallel Vectors
- Collinearity and Coplanarity of Vectors
- Product of Two Vectors > Scalar (Dot) Product
- Product of Two Vectors > Vector (Cross) Product
